EX-01
Carpal array
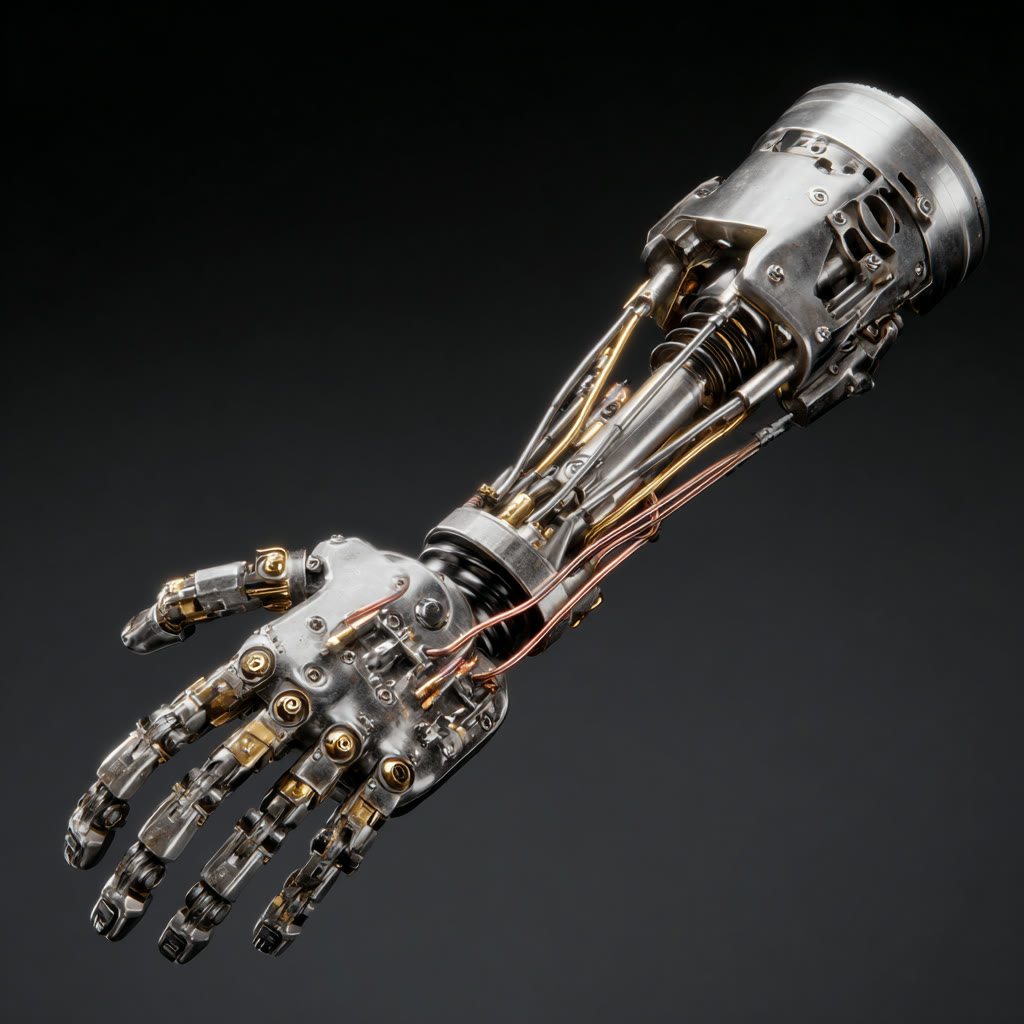
Nineteen driven axes in the span of a palm. The array resolves a grip in a single pass instead of correcting toward it.
- Axes
- 19
- Latency
- 4 ms
Where precision shapes every motion. Design defines intent. Form and function exist as one unified system.
One control loop reads every axis on the same frame, so nineteen joints behave as a single intention.
[ System ]
34
Systems designed where form aligns with action. Every element serves a defined role, balancing visual clarity with functional precision.
Function refined through structure and intent. Built to adapt, perform, and evolve consistently across dynamic environments and use cases.
27
Engineered where movement meets precision. Designed for seamless interaction, controlled performance, and fluid transitions across every state.
[ Modules ]
Each module ships as a finished system and still reads as one surface once assembled. Nothing is bolted on after the fact.
Nineteen driven axes in the span of a palm. The array resolves a grip in a single pass instead of correcting toward it.
Load is routed along woven filament rather than gearing, so the limb absorbs a shock instead of transmitting it upward.
A continuous pressure surface across the shell. Contact is read as a shape, not as a set of isolated points.
One deterministic loop for the whole chassis. Every module reads the same frame of state at the same instant.
Heat leaves through the structure itself. The frame is the radiator, which removes the fan and the noise floor with it.
Braking energy is recovered on every deceleration and held for the next actuation rather than dumped as heat.
[ Process ]
Every unit goes through the same four passes, in the same order, whether it ends up on a line in Zürich or in a lab.
We measure the task before we describe the machine. Reach, load, cadence and tolerance are recorded on site, in the environment the unit will actually work in.
The frame is resolved around those numbers. Geometry follows load path, and the visual language falls out of the structure rather than being applied to it.
Every axis is tuned against the recorded task. Response curves, damping and grip thresholds are set per deployment, never shipped as a default.
The unit enters the line with its telemetry already streaming. Drift is corrected from real operating data across the whole fleet, continuously.
A new standard where design drives performance at every level. Built to merge aesthetics with purpose, creating systems that deliver clarity, efficiency, and consistent results through intelligent structure.
0K
Units deployed
0K
System operations
0K
Active modules